Sula 8 Offshore Unmanned Surface Vessel
Sula 8 offshore unmanned surface vessel, 8 m long, for the full UXO survey stack with gradiometer and side-scan tows, sub-bottom profiler, USBL and satcom.
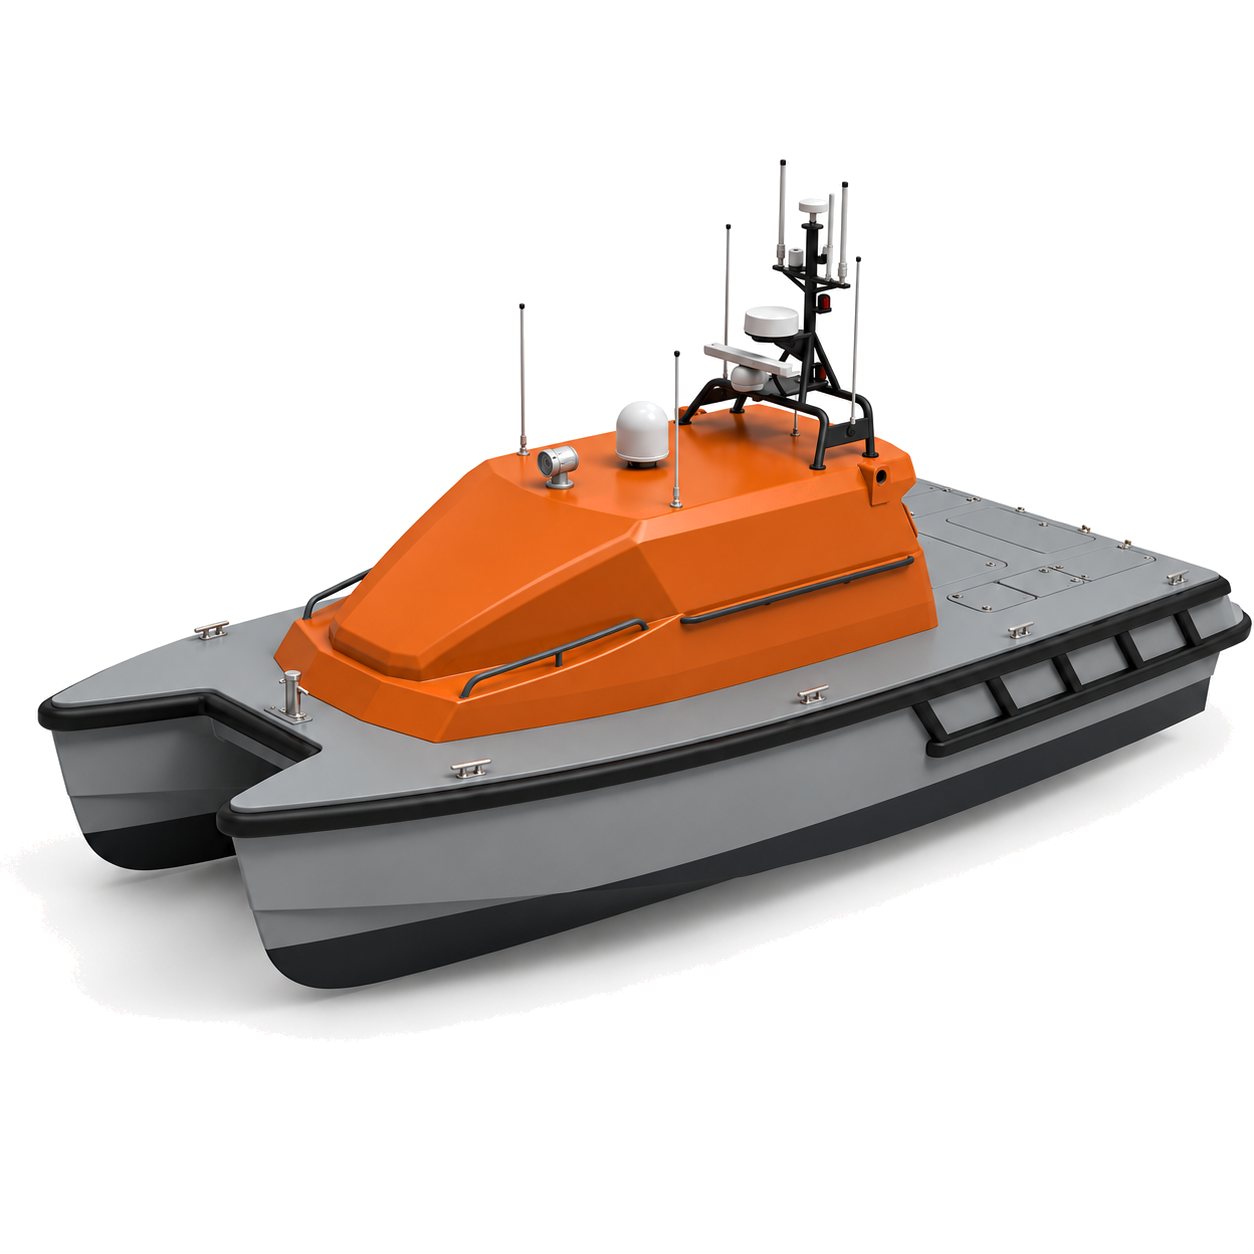
Sula 8 is a 7.8 m diesel-electric catamaran unmanned surface vessel for missions of up to 24 h. It is our platform for the full UXO survey system: two tows, such as a Geometrics G-882 TVG gradiometer and an EdgeTech 4205 side-scan, plus an Innomar SES-2000 sub-bottom profiler with survey INS, USBL tracking and a powered winch. We configure each boat to order, with RTK GNSS position and dual-antenna heading as standard.
Platform specification
Sula 8 is a 7.8 m diesel-electric catamaran with a range of up to 300 km.
| Sula 8 | |
|---|---|
| Length | 7.8 m |
| Beam | 2.8 m |
| Height | 2.5 m |
| Draft | About 1.0 m |
| Mass | About 2.4 t |
| Hull | Catamaran in polyethylene (PE) and other materials |
| Propulsion | Diesel-electric hybrid |
| Endurance | 24 h at economic speed |
| Range | Up to 300 km |
| Maximum speed | 8 kn |
| Comms | 4G, 5G and satellite; communication distance up to 50 km, extendable by relay or satellite; remote control to 10 km |
| Water | Offshore, in moderate sea conditions |
| Working temperature | −10 to +55 °C |
UXO survey configuration
Configured per project on Sula 8.
| Tow lines | Two: a magnetometer gradiometer and a side-scan sonar |
| Gradiometer | Geometrics G-882 TVG (two G-882 sensors on a frame) |
| Side-scan | Towed, with reel and depressor |
| Sub-bottom profiler | Parametric, such as the Innomar SES-2000, with a survey-grade INS |
| Towed-body tracking | USBL |
| Handling | Powered winch |
| Mission length | Up to 24 h at economic speed |
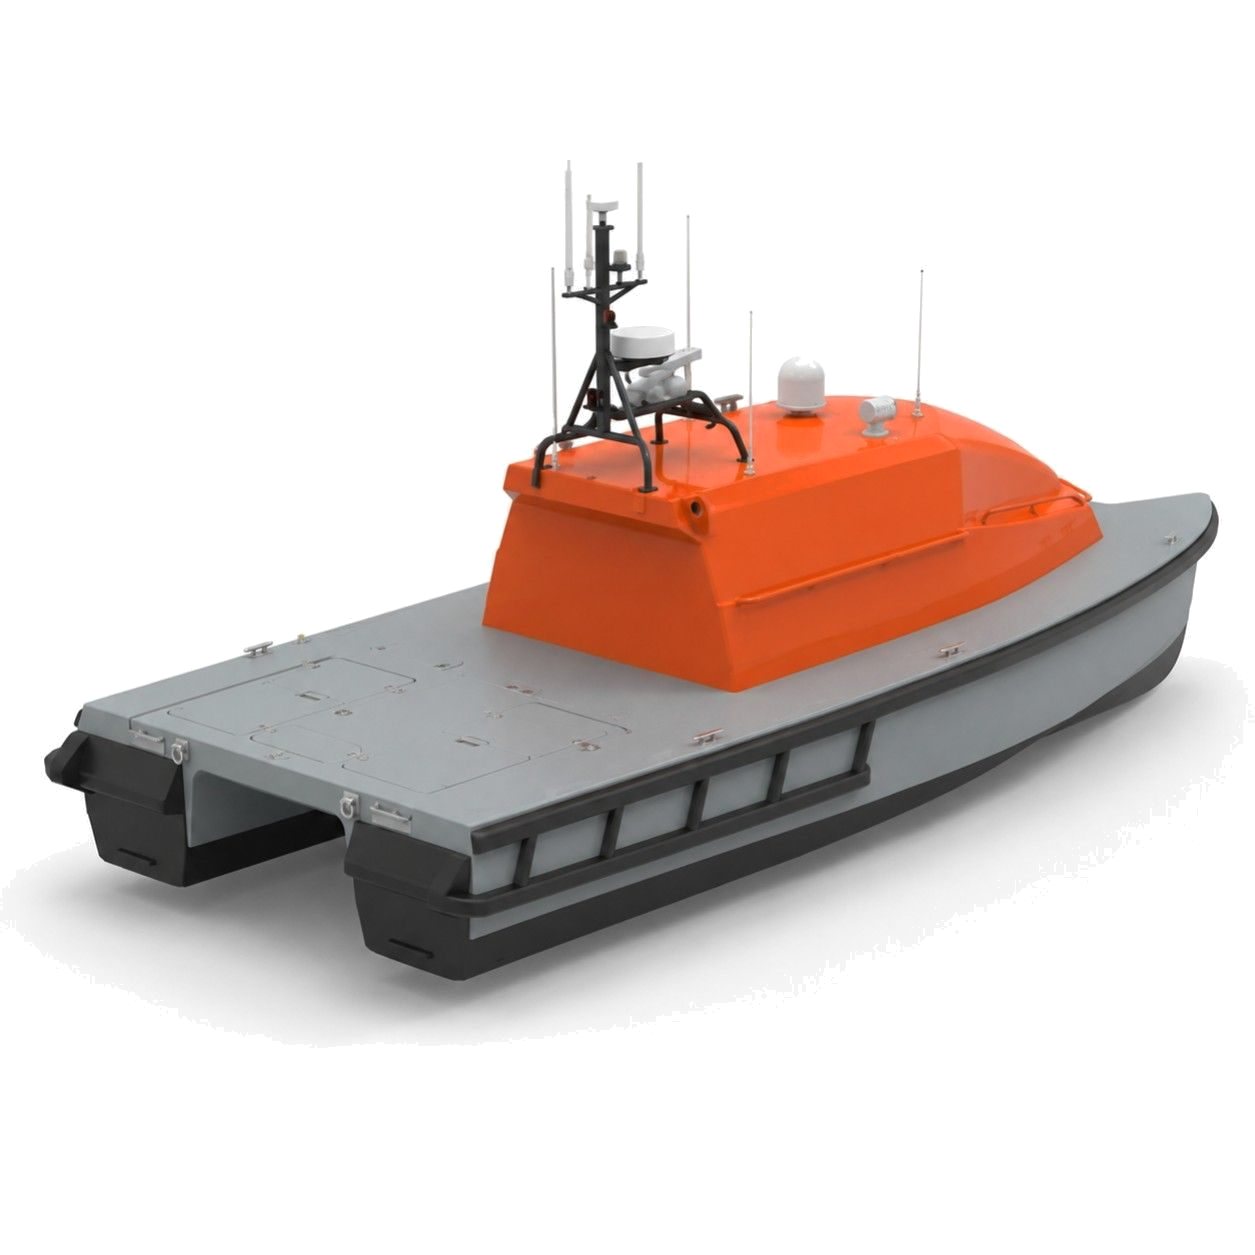
Payloads Sula 8 takes
Everything Sula 5 takes also fits. Sula 8 adds the full UXO stack and the deck equipment behind it:
| Payload | Example models | Mount | Note |
|---|---|---|---|
| Towed magnetometer or gradiometer | Geometrics G-882, G-882 TVG; Marine Magnetics SeaSPY2, Explorer, SeaQuest2; SENSYS MX3D | Towed | The first of two tows, with the sensor 3–4 m above the seabed. |
| Side-scan sonar, second tow beside a magnetometer | EdgeTech 4205; JW Fishers 450/900 CHIRP with CMS-2 reel and DDW-1 depressor | Towed | The second tow. A hull-mounted side-scan is the fallback for a hull that cannot take two tows. |
| Parametric sub-bottom profiler | Innomar SES-2000 compact, SES-2000 standard | Hull | With a survey INS. |
| USBL for a towed body | Blueprint Subsea SeaTrac X150 with X010 beacon; Sonardyne Micro-Ranger 2 | Hull | Positions the tows. Layback from a winch cable counter is the cross-check. |
| Powered winch | EIVA OceanEnviro 1.7 (650 m of 4.6 mm cable, 2 kN, slip ring) | Deck | The winch weighs 285 kg. |
| Iridium Certus satcom | Thales VesseLINK 200; Thales MissionLINK 700 | Mast | The backup to Starlink beyond line of sight. |
Step down to Sula 5 for a single magnetometer tow, a sub-bottom profiler or a towed side-scan in harbours and near-shore water.
Applications
- Offshore-wind pre-construction UXO survey.
- Cable-route UXO and geophysical survey.
- Offshore multibeam and sub-bottom survey.
- Water-column and metocean work: ADCP, sound velocity and CTD.
- Over-the-horizon operations with Starlink and Iridium Certus back to shore.
Sula 8 works offshore and launches from a harbour or a host vessel.
Navigation
Standard: RTK GNSS position with dual-antenna heading. One survey GNSS/INS is the reference for every sensor, with PPS time sync. The RTK correction feed comes from a base station or from network corrections over mobile data.
Option: anti-jam navigation. Pro is the natural tier for Sula 8, and the Base set also fits.
- Pro: a multi-element CRPA with null-steering, a tactical-grade fibre-optic-gyro (FOG) inertial unit, and a flush-mount surface-vessel Doppler velocity log (DVL) in a sea valve or bell housing.
- Base: a filtered anti-jam antenna, a compact inertial unit of industrial (MEMS) or lower tactical grade, and a compact DVL.
With either set, spoofing detection with automatic source switching is configured and integrated per boat, and integration with the autopilot is available. DVL bottom-lock needs the seabed within range, which means shallow and coastal water; in deep water the DVL falls back to water-track, and drift then depends on the inertial unit’s grade. More on the tiers: GNSS-denied USV navigation.
Integration and support
| Integration | Payload fitted, wired and calibrated on the hull, with sensor offsets and parameters set and the RTK correction feed configured. Autopilot integration is available. |
| Delivery | Commissioning on your water, operator training, and support from our UK and EU teams. |
| Ordering | Configured to order, quoted per boat. |
Questions and answers
What sensor height and track-keeping does a USV magnetometer survey need?
The towed sensor flies 3–4 m above the seabed, and 1–2 m line spacing needs track-keeping within ±0.5–1 m.
Which inertial navigation grade suits an offshore USV?
With survey payloads aboard, one survey GNSS/INS is the reference for every sensor. For anti-jam navigation, the Pro set carries a tactical-grade fibre-optic-gyro inertial unit, and the Base set also fits.
Discuss a USV
Tell us about the payload, the water you work on and how long each mission runs.
